ForceN teaches force and torque sensing for humanoids at RoboBusiness
ForceN will host a session titled A Crash Course in Force & Torque Sensing for Humanoids at RoboBusiness 2026 on October 20–21 in Santa Clara, California. Robert Brooks, the company’s CEO and founder, will speak at 2:15 p.m. PT on October 20. The talk will cover how force and torque sensors enable humanoid robots to handle objects with precision, avoiding damage while working in industrial or…
Key points
- ForceN’s Robert Brooks teaches force/torque sensing for humanoids at RoboBusiness 2026 on Oct. 20 at 2:15 p.m. PT
- Session covers lessons from three years working with top humanoid companies and unstructured robotics sectors
- Focus on avoiding sensor damage and integrating sensors into humanoid designs for precision tasks
Brooks will draw on three years of experience collaborating with leading humanoid manufacturers. He will share insights from ForceN’s work across surgical, logistics, space, and food/agricultural robotics, emphasizing best practices for integrating sensors into humanoid designs. The session aims to accelerate production and field readiness of humanoid robots by addressing common challenges in force/torque sensing applications.
ForceN to give a crash course on force and torque sensing for humanoids at RoboBusiness
The Robot Report · 29 September 2026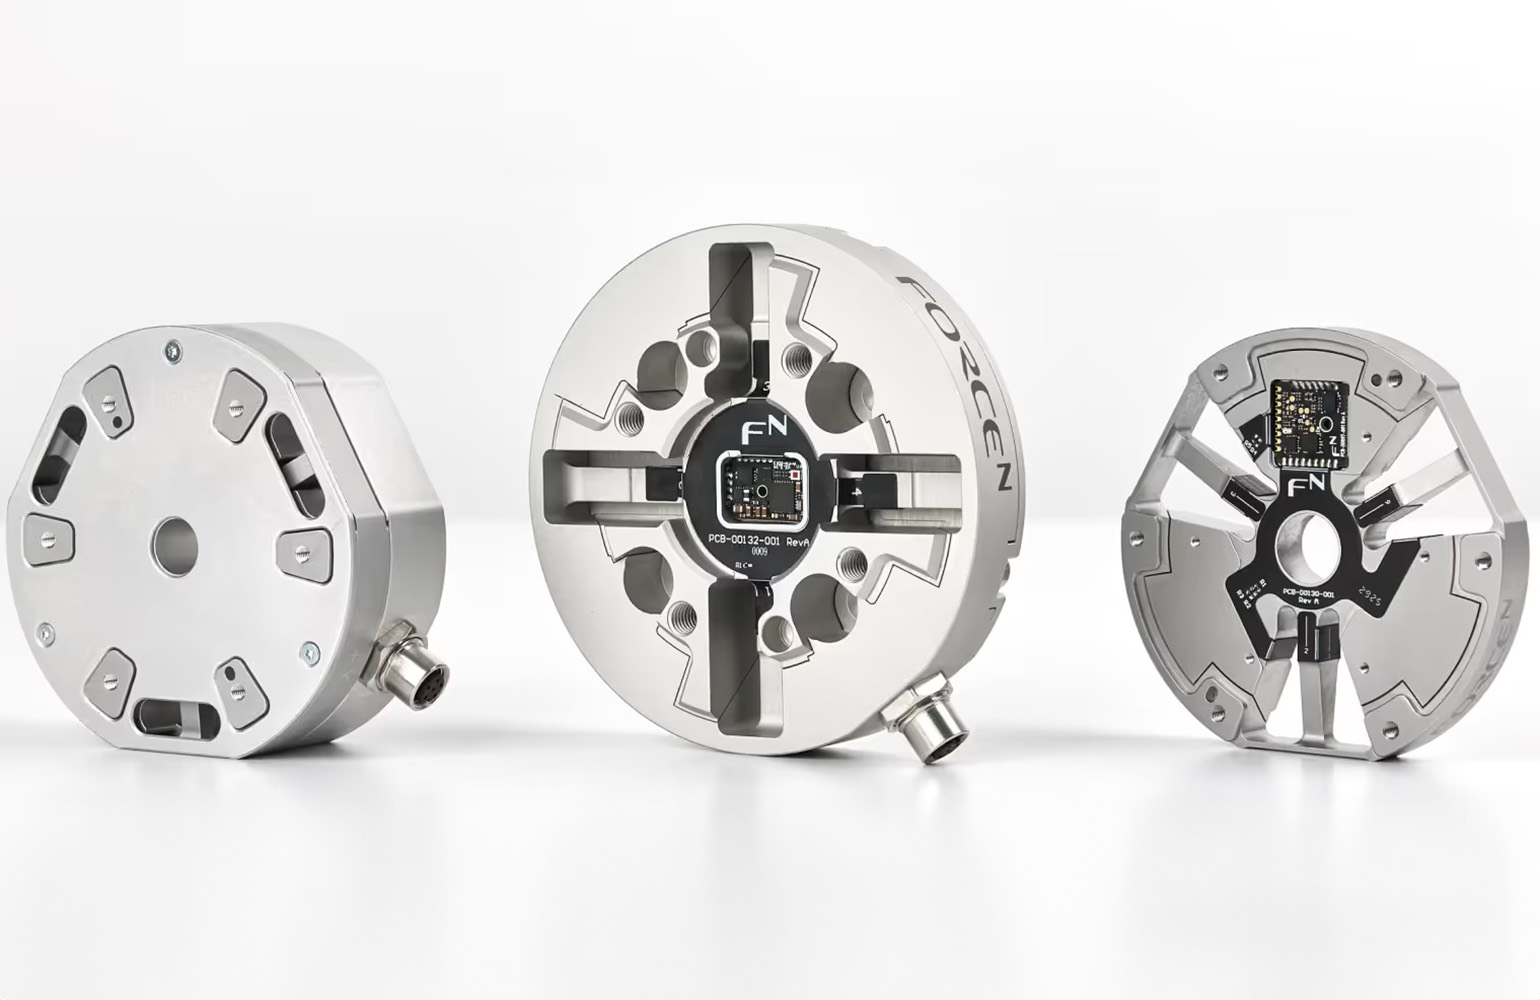
Loading the full article…
This text was published by The Robot Report and written by The Robot Report Staff. It is reproduced here with attribution so you can read it in full; the rights remain with the publisher. Read it at the source ↗
The headline, key points and digest above were generated by Digest AI's editorial model from the linked sources. Automated summaries can contain errors: the sources are the record. Spotted a mistake? Tell us. Published by Martin K., who runs Digest AI and handles corrections.
More in Robotics & Physical AI
All →- Manufacturing Robot orders rise 6.6% year over year, Report says · 1 src
- Charlie Kemp builds assistive robots at Hello Robot · 1 src
- AI Robotics Alliance debates robot economic autonomy and crypto wallets for humanoids · 1 src
- Raise Robotics shares leadership framework for scaling field robots at RoboBusiness · 1 src
- NASA tests generative AI for spacecraft autonomy on Mars rover and ISS · 1 src
Comments
via GitHub Discussions