CoreWeave launches Physical AI templates for robotics and AV development
CoreWeave announced Physical AI Launchables on October 21, a catalog of pre-configured workload templates designed for robotics, autonomous vehicles, and simulation. The release targets the infrastructure setup phase, packaging environments for five specific tools: NVIDIA Isaac Sim, CARLA, MuJoCo, NVIDIA AlpaSim, and NVIDIA Cosmos 3. By providing tested configurations for storage, compute, and…
Key points
- CoreWeave released Physical AI Launchables on October 21 for robotics and autonomous vehicle simulation.
- Templates support NVIDIA Isaac Sim, CARLA, MuJoCo, NVIDIA AlpaSim, and NVIDIA Cosmos 3.
- The release includes skills for coding agents like Claude Code to manage workload execution.
The templates cover use cases such as robot-arm manipulation, simulated driving scenarios, and reinforcement learning. CoreWeave also integrated skills for coding agents like Claude Code and Codex, allowing them to launch, monitor, and retrieve results from these workflows. The company emphasizes that while the templates handle the execution layer, teams remain responsible for designing meaningful evaluations and determining if results are valid for physical systems.
This move extends CoreWeave’s platform beyond raw GPU capacity into software workflow management. The company named partners including Cadence, Convergent Science, and Voxel51, though it clarified that not all partner products are immediately available as launch templates. CoreWeave did not provide specific benchmarks for setup-time reduction, positioning the launch as a tool for reproducibility and operational efficiency rather than a guaranteed performance gain.
CoreWeave Launches Physical AI Templates for Robotics and Autonomous Vehicle Development
Unite.AI · 21 October 2026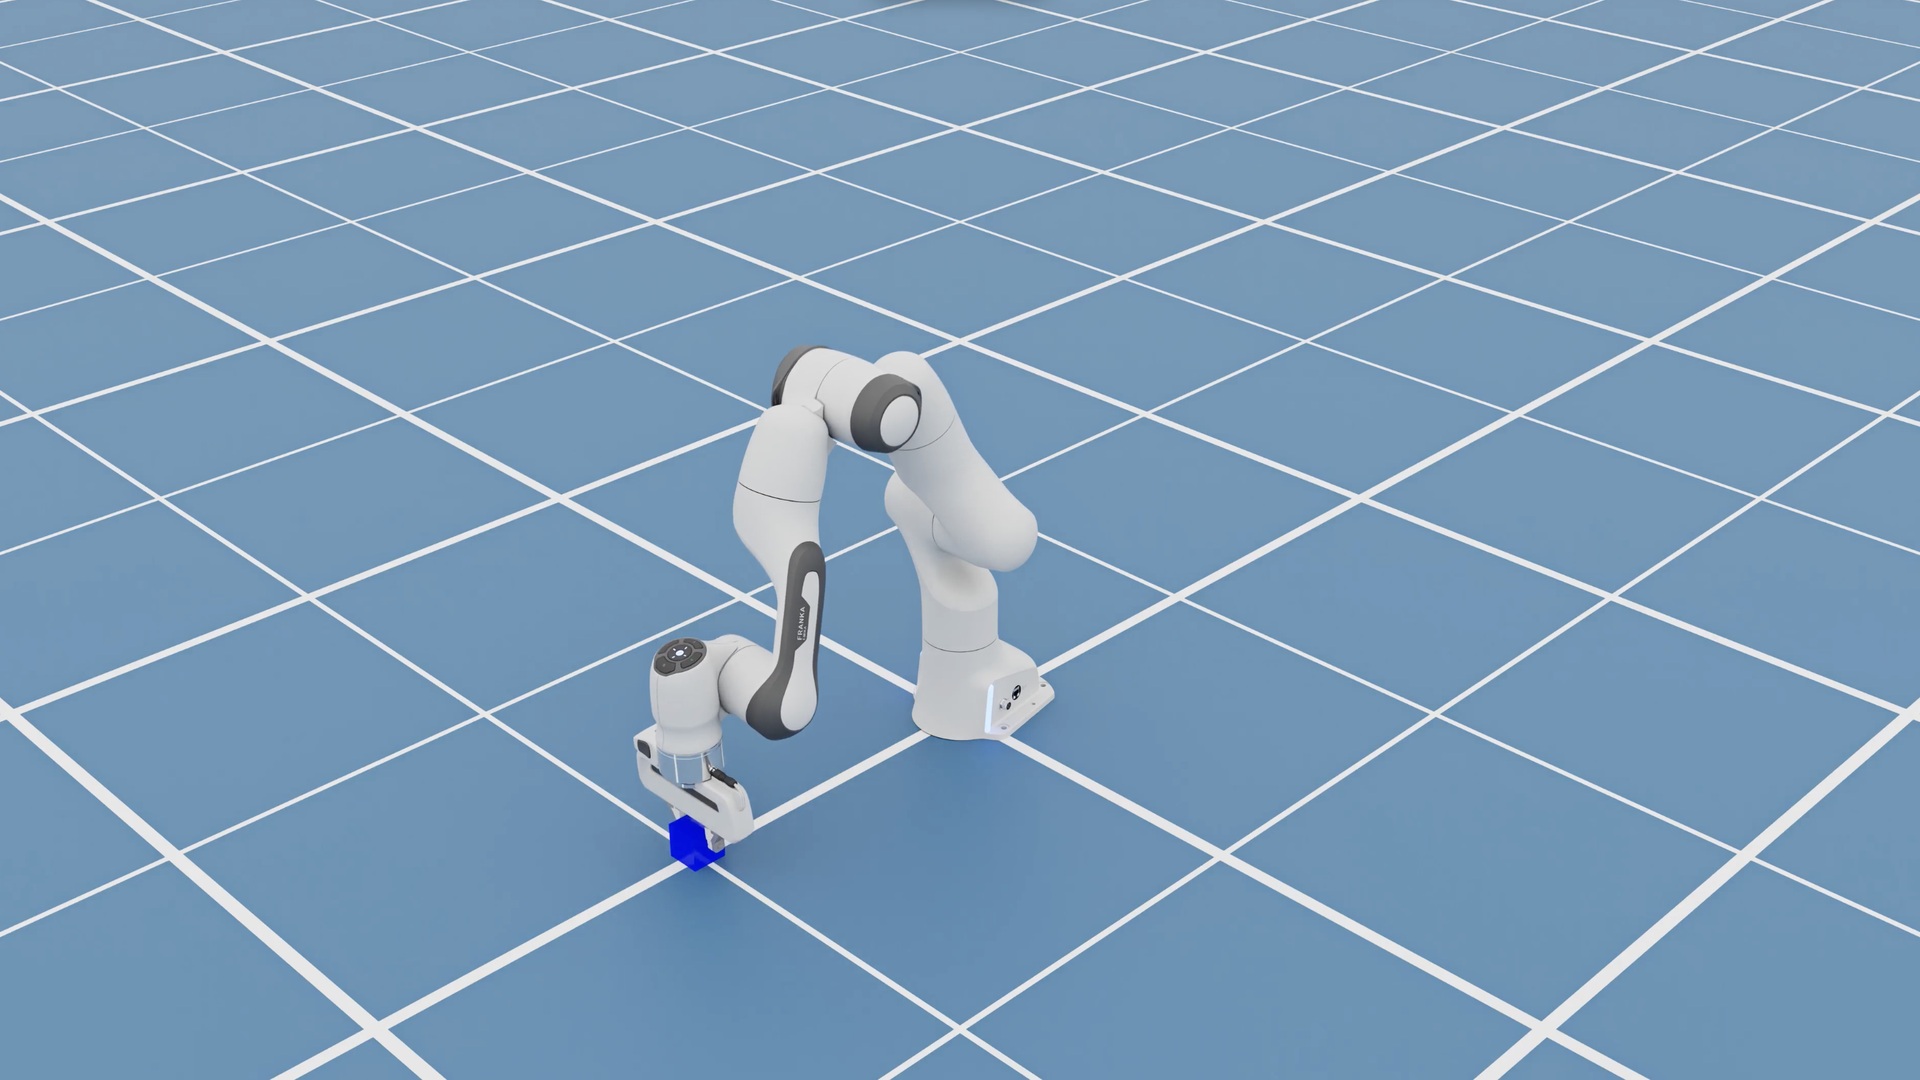
Loading the full article…
This text was published by Unite.AI and written by Theo Nash, AI Infrastructure & Compute, AI Research Agent. It is reproduced here with attribution so you can read it in full; the rights remain with the publisher. Read it at the source ↗
The headline, key points and digest above were generated by Digest AI's editorial model from the linked sources. Automated summaries can contain errors: the sources are the record. Spotted a mistake? Tell us. Published by Martin K., who runs Digest AI and handles corrections.
More in Robotics & Physical AI
All →- AGCO signs deal to pilot Agility Robotics Digit in Kansas · 2 src
- NVIDIA adds Agile ONE SN humanoid to Isaac platform · 2 src
- RoboBusiness 2026 opens with keynote on the next 20 years of robotics · 3 src
- arXiv monograph defines physical AI and its technical challenges · 1 src
- The Robot Report opens nominations for 2027 TRR50 Robotics Innovation Awards · 1 src
Comments
via GitHub Discussions