Raise Robotics shares leadership framework for scaling field robots at RoboBusiness
Raise Robotics will present a leadership framework for scaling autonomous robots in construction at RoboBusiness 2026. Kenrick Tjandra, who leads robotics deployment at the San Francisco-based company, will discuss how to bridge the gap between lab performance and real-world use. His approach focuses on operator discipline over hardware fixes, based on 10 projects across eight states and over…
Key points
- Raise Robotics holds U.S. commercial record for autonomous robots installing building envelopes, with 10 projects across eight states
- Kenrick Tjandra’s framework distinguishes between product fixes and operator discipline for scaling robots in the field
- Framework peer-reviewed by Project Production Institute, with lessons adopted by the International Union of Painters
The framework, peer-reviewed by the Project Production Institute, identifies three key challenges: sampling bias, margin stacking, and capability-envelope variance. Tjandra will also share operator-training lessons adopted by the International Union of Painters and Allied Trades. The session takes place on October 20 at 1:15 p.m. ET in Santa Clara, California.
Raise Robotics to discuss scaling field robots at RoboBusiness
The Robot Report · 28 September 2026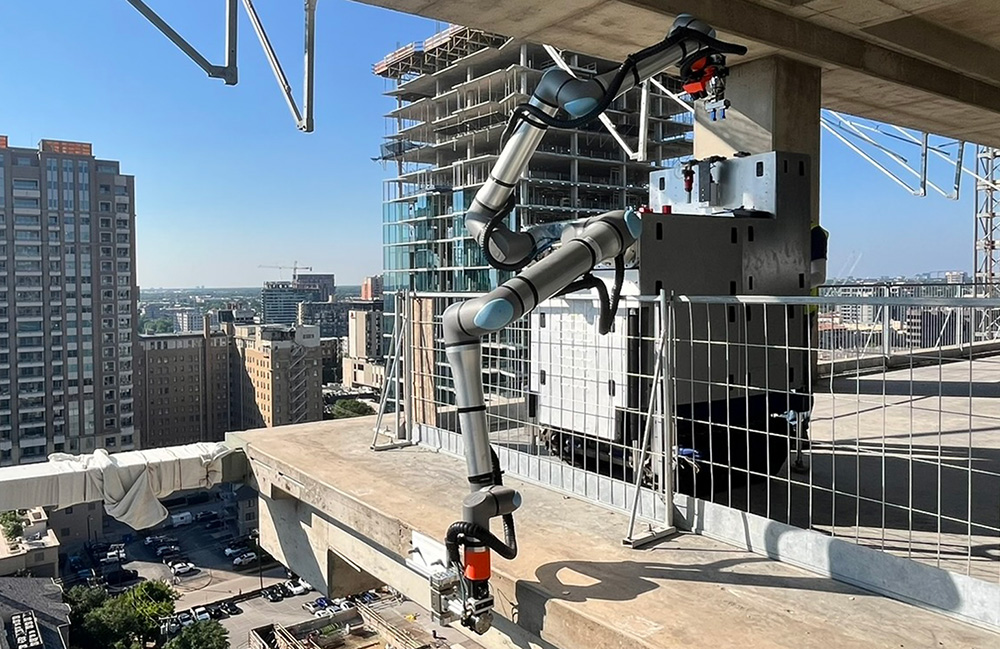
Loading the full article…
This text was published by The Robot Report and written by The Robot Report Staff. It is reproduced here with attribution so you can read it in full; the rights remain with the publisher. Read it at the source ↗
The headline, key points and digest above were generated by Digest AI's editorial model from the linked sources. Automated summaries can contain errors: the sources are the record. Spotted a mistake? Tell us. Published by Martin K., who runs Digest AI and handles corrections.
More in Robotics & Physical AI
All →- Tesla ramps up Optimus robot production to several hundred units per week · 2 src
- Amazon invests $100M in Indiana robotics facility for fulfillment and AI-powered systems · 1 src
- Unitree deploys 19 humanoid robots in AI-driven WorldSkills Shanghai 2026 performance · 1 src
- Agility Robotics CEO says company is exploring wheeled robots · 1 src
- CNH Industrial highlights robotics to address farming labor and efficiency challenges · 1 src
Comments
via GitHub Discussions