LiberAI releases Liber-0 world action model with 36% zero-shot robot success
LiberAI, a Beijing-based startup, introduced Liber-0, a world action model pretrained on 2.2 million hours of human experience to enable zero-shot robot manipulation. The model combines human video, glove-recorded hand motion, and embodiment-conditioned learning to transfer human manipulation skills to robots without task-specific robot demonstrations.
Key points
- Liber-0 achieves 36% zero-shot success on 60 GPT-6 tasks without robot-specific training
- Pretrained on 2.2M+ hours of human video and glove-recorded hand motion data
- LiberSense Glove reduces robot demonstration needs by up to 75% per LiberAI’s tests
Liber-0 was tested on 60 GPT-6-proposed tasks, achieving a 36% overall success rate across 600 trials. Breakdowns show 63.5% success on pick-and-place tasks, 34% on non-pick-and-place manipulation, and 10.5% on challenging multi-step tasks. The model uses LiberSense Glove, a data-collection system that records precise hand movements, alongside a robot platform designed to mimic human motion. LiberAI claims this approach reduces reliance on expensive, task-specific robot demonstrations by up to 75%, as shown in controlled experiments. The startup also highlights that the pretrained model already captures most task capabilities, with minimal gains from additional robot post-training.
Model page: GPT-6 →
LiberAI Unveils Liber-0, a World Action Model That Grounds Human Experience in Robot Action
The Robot Report · 4 November 2026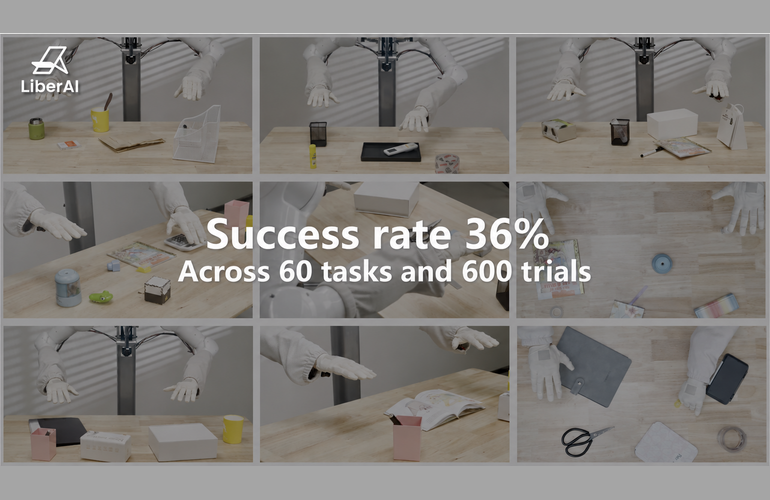
Loading the full article…
This text was published by The Robot Report and written by Sponsored Content. It is reproduced here with attribution so you can read it in full; the rights remain with the publisher. Read it at the source ↗
The headline, key points and digest above were generated by Digest AI's editorial model from the linked sources. Automated summaries can contain errors: the sources are the record. Spotted a mistake? Tell us. Published by Martin K., who runs Digest AI and handles corrections.
More in Robotics & Physical AI
All →- The Robot Report releases 2026 Robotics Startup Radar · 1 src
- GlobalLogic builds UV disinfection robot for Haystack Robotics · 1 src
- Realbotix renames Echo humanoid robots as Series 1 to avoid trademark issues · 1 src
- Dimensional pays humans $20/hour to walk robot dogs for AI training · 1 src
- KIST researcher Lee Jong-won wins Korea Science Award for KAPEX humanoid · 1 src
Comments
via GitHub Discussions