Nvidia releases Isaac ROS 5.0 with agentic workflows and ROS Lyrical support
Nvidia announced Isaac ROS 5.0 at the ROSCon conference in Toronto, adding GPU‑accelerated packages to the open‑source ROS ecosystem. The update brings support for ROS Lyrical and Ubuntu 24.04, letting developers run demanding robotics workloads on NVIDIA hardware while staying within familiar open‑source tools.
Key points
- Isaac ROS 5.0 adds ROS Lyrical and Ubuntu 24.04 support for GPU‑accelerated robotics workloads.
- New skills include FoundationStereo fine‑tuning and FoundationPose inference, with pose estimation up to 5.5x faster.
- The framework is free, open source and runs on Jetson Orin Nano through Jetson Thor devices.
New agent‑ready skills include a FoundationStereo fine‑tuning skill for adapting stereo perception models and a FoundationPose inference library that claims pose estimation up to 5.5x faster. The release also bundles a pick‑and‑place workflow as a standalone skill and integrates with the Open Source Robotics Alliance’s data‑handling interface for consistent GPU acceleration across platforms.
Isaac ROS 5.0 is free and open source, and it runs on NVIDIA Jetson devices from Orin Nano to Jetson Thor. Early adopters such as RealSense, Intrinsic, Seeed Studio, Magna, and others are already pairing the stack with edge hardware to build perception, navigation and manipulation applications for industrial and research robots.
The story so far
2 episodes →- Nvidia releases Isaac ROS 5.0 with agentic workflows and ROS Lyrical supportthis story
NVIDIA Isaac ROS 5.0 Advances Agentic, Open Source Robotics Development
NVIDIA Blog · 22 September 2026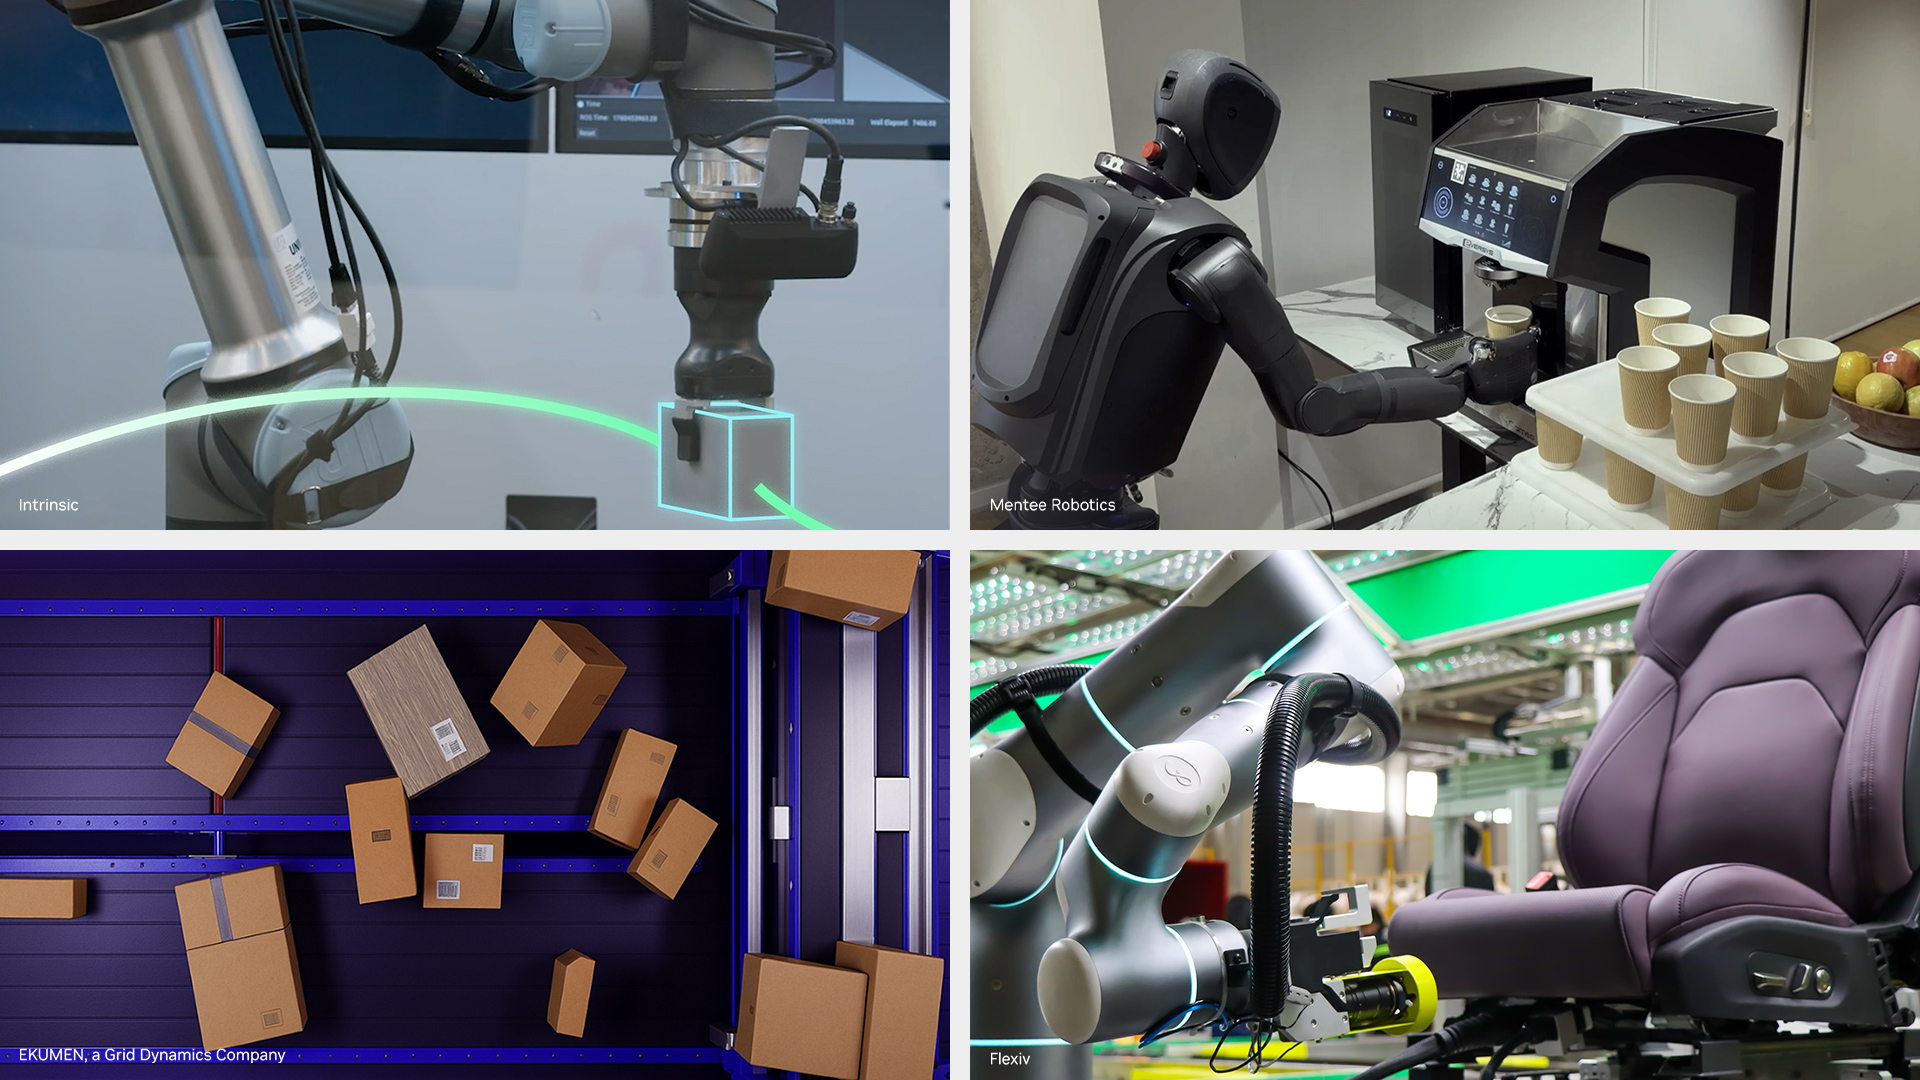
Loading the full article…
This text was published by NVIDIA Blog and written by Katie Washabaugh. It is reproduced here with attribution so you can read it in full; the rights remain with the publisher. Read it at the source ↗
The headline, key points and digest above were generated by Digest AI's editorial model from the linked sources. Automated summaries can contain errors: the sources are the record. Spotted a mistake? Tell us. Published by Martin K., who runs Digest AI and handles corrections.
More in Agents & Tools
All →- Opinion: AI struggles to evaluate code maintainability, says developer · 1 src
- Meta's Muse AI agent tops US App Store, drives stock surge · 13 src
- Amazon blocks Meta's Muse AI agent from shopping on its site over credential and access concerns · 14 src
- Security researcher shows hidden Muse setting could let attackers turn Muse into backdoor · 2 src
- JetBrains launches Air system for agentic software development · 1 src
Comments
via GitHub Discussions