A3 publishes ISO 21423 standard for cross-vendor industrial mobile robot communication
The standard, developed by ISO Technical Committee 299, defines communication protocols for automated guided vehicles (AGVs), autonomous mobile robots (AMRs), and related systems to share data like location, speed, task status, and availability.
Key points
- ISO 21423:2026 standardizes communication between IMRs from different vendors, including AGVs and AMRs
- Robots can now share real-time data like location, speed, and task status to avoid collisions and improve efficiency
- Standard also integrates with ERP systems, building infrastructure, and human mobile devices, costing $373 publicly
A3 says the standard reduces collisions and path conflicts, boosting efficiency and system reliability. It also enables robots to integrate with enterprise resource planning (ERP) tools, building systems (e.g., lifts, alarms), and human workers using mobile devices. Carole Franklin, A3’s director of robotics standards, noted demand from industrial users for years. The standard costs $373 publicly or $320 for A3 members, reflecting its technical depth. A3, with over 1,500 member organizations, positions this as its first non-safety robotics standard, signaling broader industry alignment.
New ISO interoperability standard covers collaboration among mobile robots from multiple vendors
The Robot Report · 3 November 2026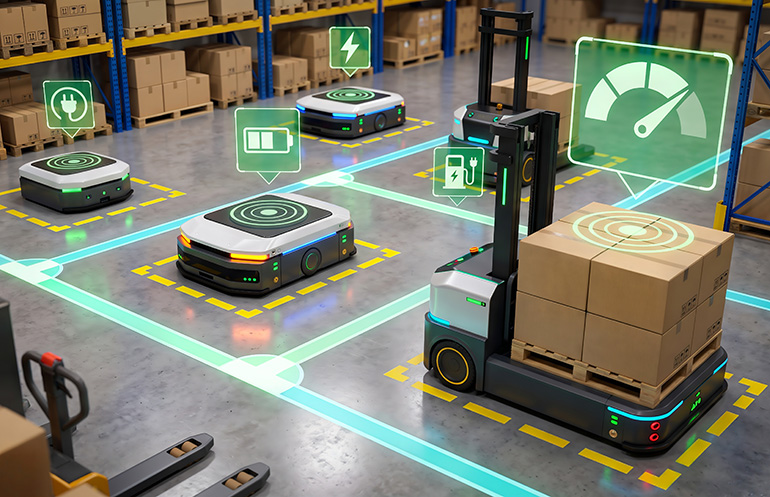
Loading the full article…
This text was published by The Robot Report and written by The Robot Report Staff. It is reproduced here with attribution so you can read it in full; the rights remain with the publisher. Read it at the source ↗
The headline, key points and digest above were generated by Digest AI's editorial model from the linked sources. Automated summaries can contain errors: the sources are the record. Spotted a mistake? Tell us. Published by Martin K., who runs Digest AI and handles corrections.
More in Robotics & Physical AI
All →- PATEO deploys NVIDIA Nemotron and ByteDance Doubao in AI Box · 2 src
- Agility Robotics shareholders approve $2.5B SPAC merger · 1 src
- Tutor Intelligence raises $75M Series B to expand robotics training and deployments · 2 src
- Agility Robotics deploys Digit at AGCO’s Kansas factory for 2027 · 1 src
- NATO tests AI agents for 5G-based drone detection in Latvia · 1 src
Comments
via GitHub Discussions